SMILE Robotics Lab
We design Soft, Modular, Intelligent, Learning, and Embodied robotic systems — advancing adaptive, cooperative, and reconfigurable robots.


Faculty
 Luyang Zhao
Members
 Yinhong Qin
Ph.D. Student
(Fall 2025 - Present)
 Arifur Rahman
(Fall 2026 - Present)
 Dixiang Wang
(Fall 2026 - Present)
 Melody Enwerem
(Fall 2026 - Present)
 Nicholas R. Burns
(May 2026 - Present)
 Alex Tabaku
(May 2026 - Present)
 Bryson Mathew Still
(May 2026 - Present)
 Clejah Nathello Daniel
(May 2026 - Present)
 Liam Leo Loughead
(May 2026 - Present)
 Kevius Tribble
(July 2026 - Present)
Creative Inquiry Teams
Soft Modular Robotic Hand
Fall 2026- Andry Janluca Aguero
- Mars Early
- Tommy Guise
- Cayden Johnson
- Caleb Z Kim
- Addie King
- Yamil Ernesto Perez
- Kirsten Clement Reed
- Kevius Tribble
- Jorge Y Valdez Reyna
LLM-Driven Robotics
Fall 2026- Breckenridge Slade Alexander
- Michael Angelo D'Anton IV
- Clejah Nathello Daniel
- Jesse Lin
- Yamil Ernesto Perez
- Amolik Sinha
- Kevius Tribble
Soft Modular Robotic Hand
Spring 2026- Andry Janluca Aguero
- Colton Barry
- Gina Evelyn Bertotti
- Jacob Wayne Brinson
- Caleb Z Kim
- Adalene P King
- Anish Kulkarni
- Liam Leo Loughead
- SrikarNag Nallam
- Kirsten Clement Reed
- Lucaya Robertson
- Alby Schirippa
- Alex Tabaku
- Jorge Y Valdez Reyna
LLM-Driven Robotics
Spring 2026- Ben Bedingfield
- Clejah Nathello Daniel
- Austin C Hill
- Caleb Z Kim
- Ethan Hayden M Mago
- Ethan Patrick Santee
- Alex Tabaku
- Amolik Sinha
Alumni (SMILE Robotics Lab, Clemson University)
- Minghao Zha - M.S. Student (Fall 2025 - Summer 2026)
Alumni (Mentored at Dartmouth Reality & Robotics Lab)
- Chun-Yi She - M.S. Student (2023 - 2025)
- Yitao Jiang - M.S. Student (2022 - 2025), Now Ph.D. Student at Dartmouth
- Yijia Wu - M.S. Student (2021 - 2022), Now Ph.D. Student at Tufts University
- Weishu Zhan - M.S. Student (2022 - 2023), Now Ph.D. Student at University of Manchester
- Josiah Putman - Undergraduate Researcher, Now at Google
- Maxine Perroni-Scharf - Undergraduate Researcher, Now Ph.D. Student at MIT
Intelligence by Design
Research
We design adaptable robot bodies and develop the computational tools and assembly methods that bring them to life.
Human-Driven Physical Robot Design
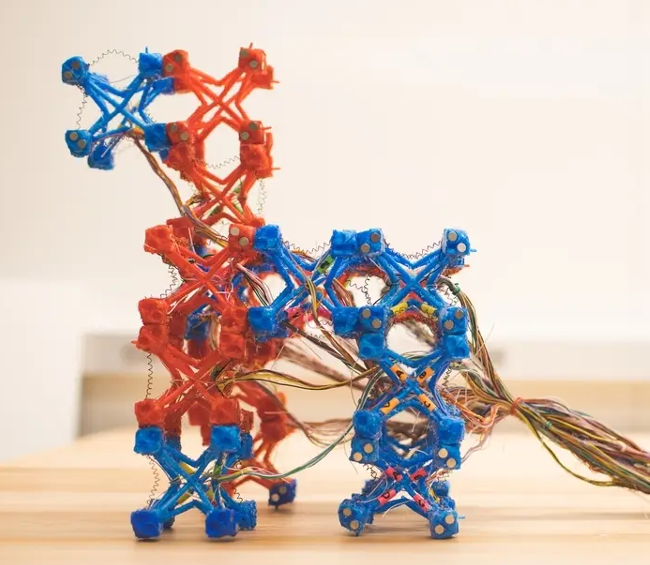
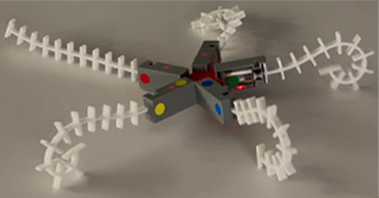
Soft, modular, and tensegrity structures give robots new ways to move, adapt, and interact.
Selected publications
View publications- Tensegrity-Blocks Nature Communications, 2025
- StarBlocks IEEE Robotics and Automation Letters, 2023
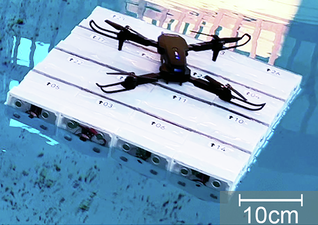
- SoftRafts npj Robotics, 2026
- SoftSnap Soft Robotics, 2025
Computational Design & Optimization
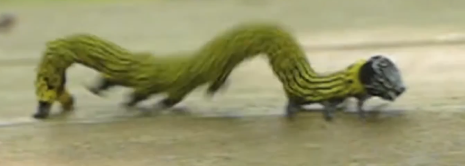
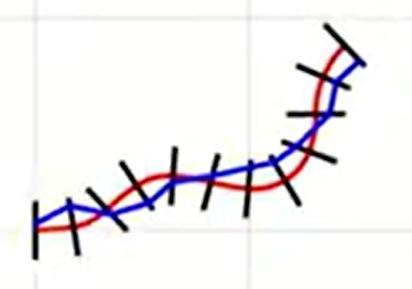
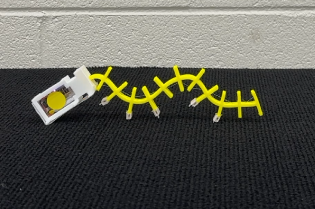
Physics-based models and learned inverse design turn desired shapes into realizable robot bodies.
Selected publications
View publications- From Biological Curves to Soft Modular Robots Preprint, 2026
- Tensegrity Dolphin RoboSoft, 2025
- Tensegrity Morphing Airfoil AIAA SciTech Forum, 2026
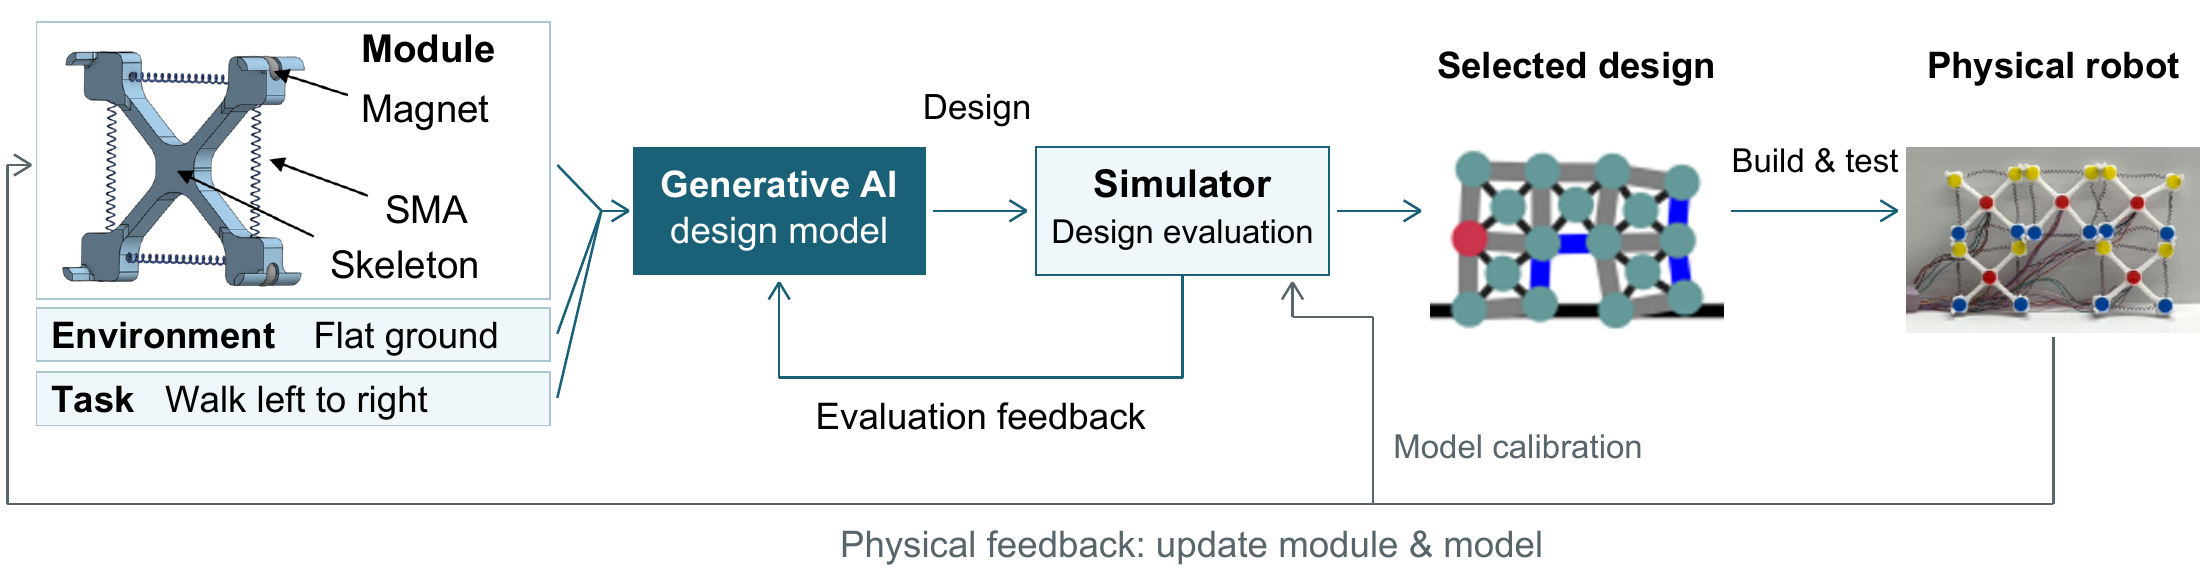
AI-Driven Robot Design
Language models and simulation feedback guide the search for robot morphologies and control.
Specify
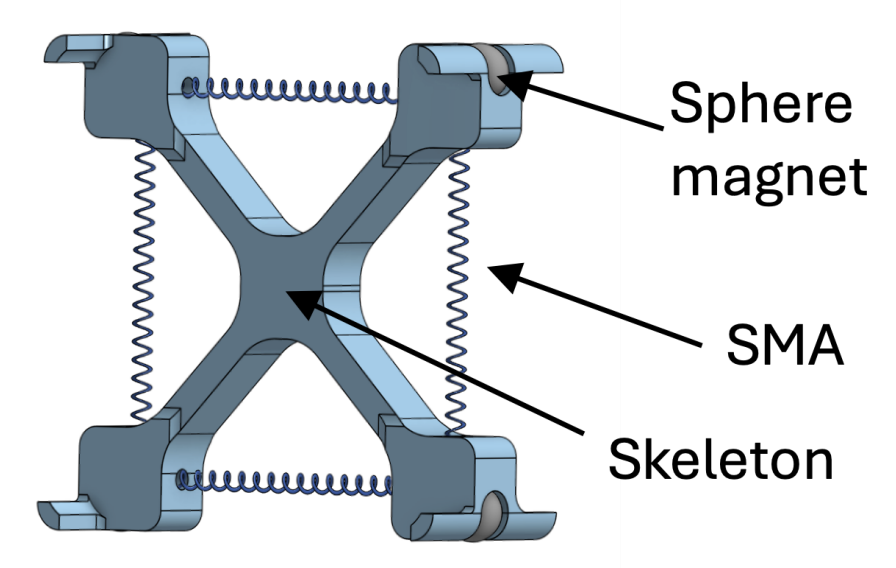
Generate & evaluate
Test & calibrate
Selected publication
View publications- LM-Based Soft Modular Robot Design Preprint, 2024
Robotic Manipulation & Assembly
We study language-conditioned manipulation and modular construction, from learned action policies to physical assembly.
VLA-based manipulation
PreprintTask Move the red object to the red target.
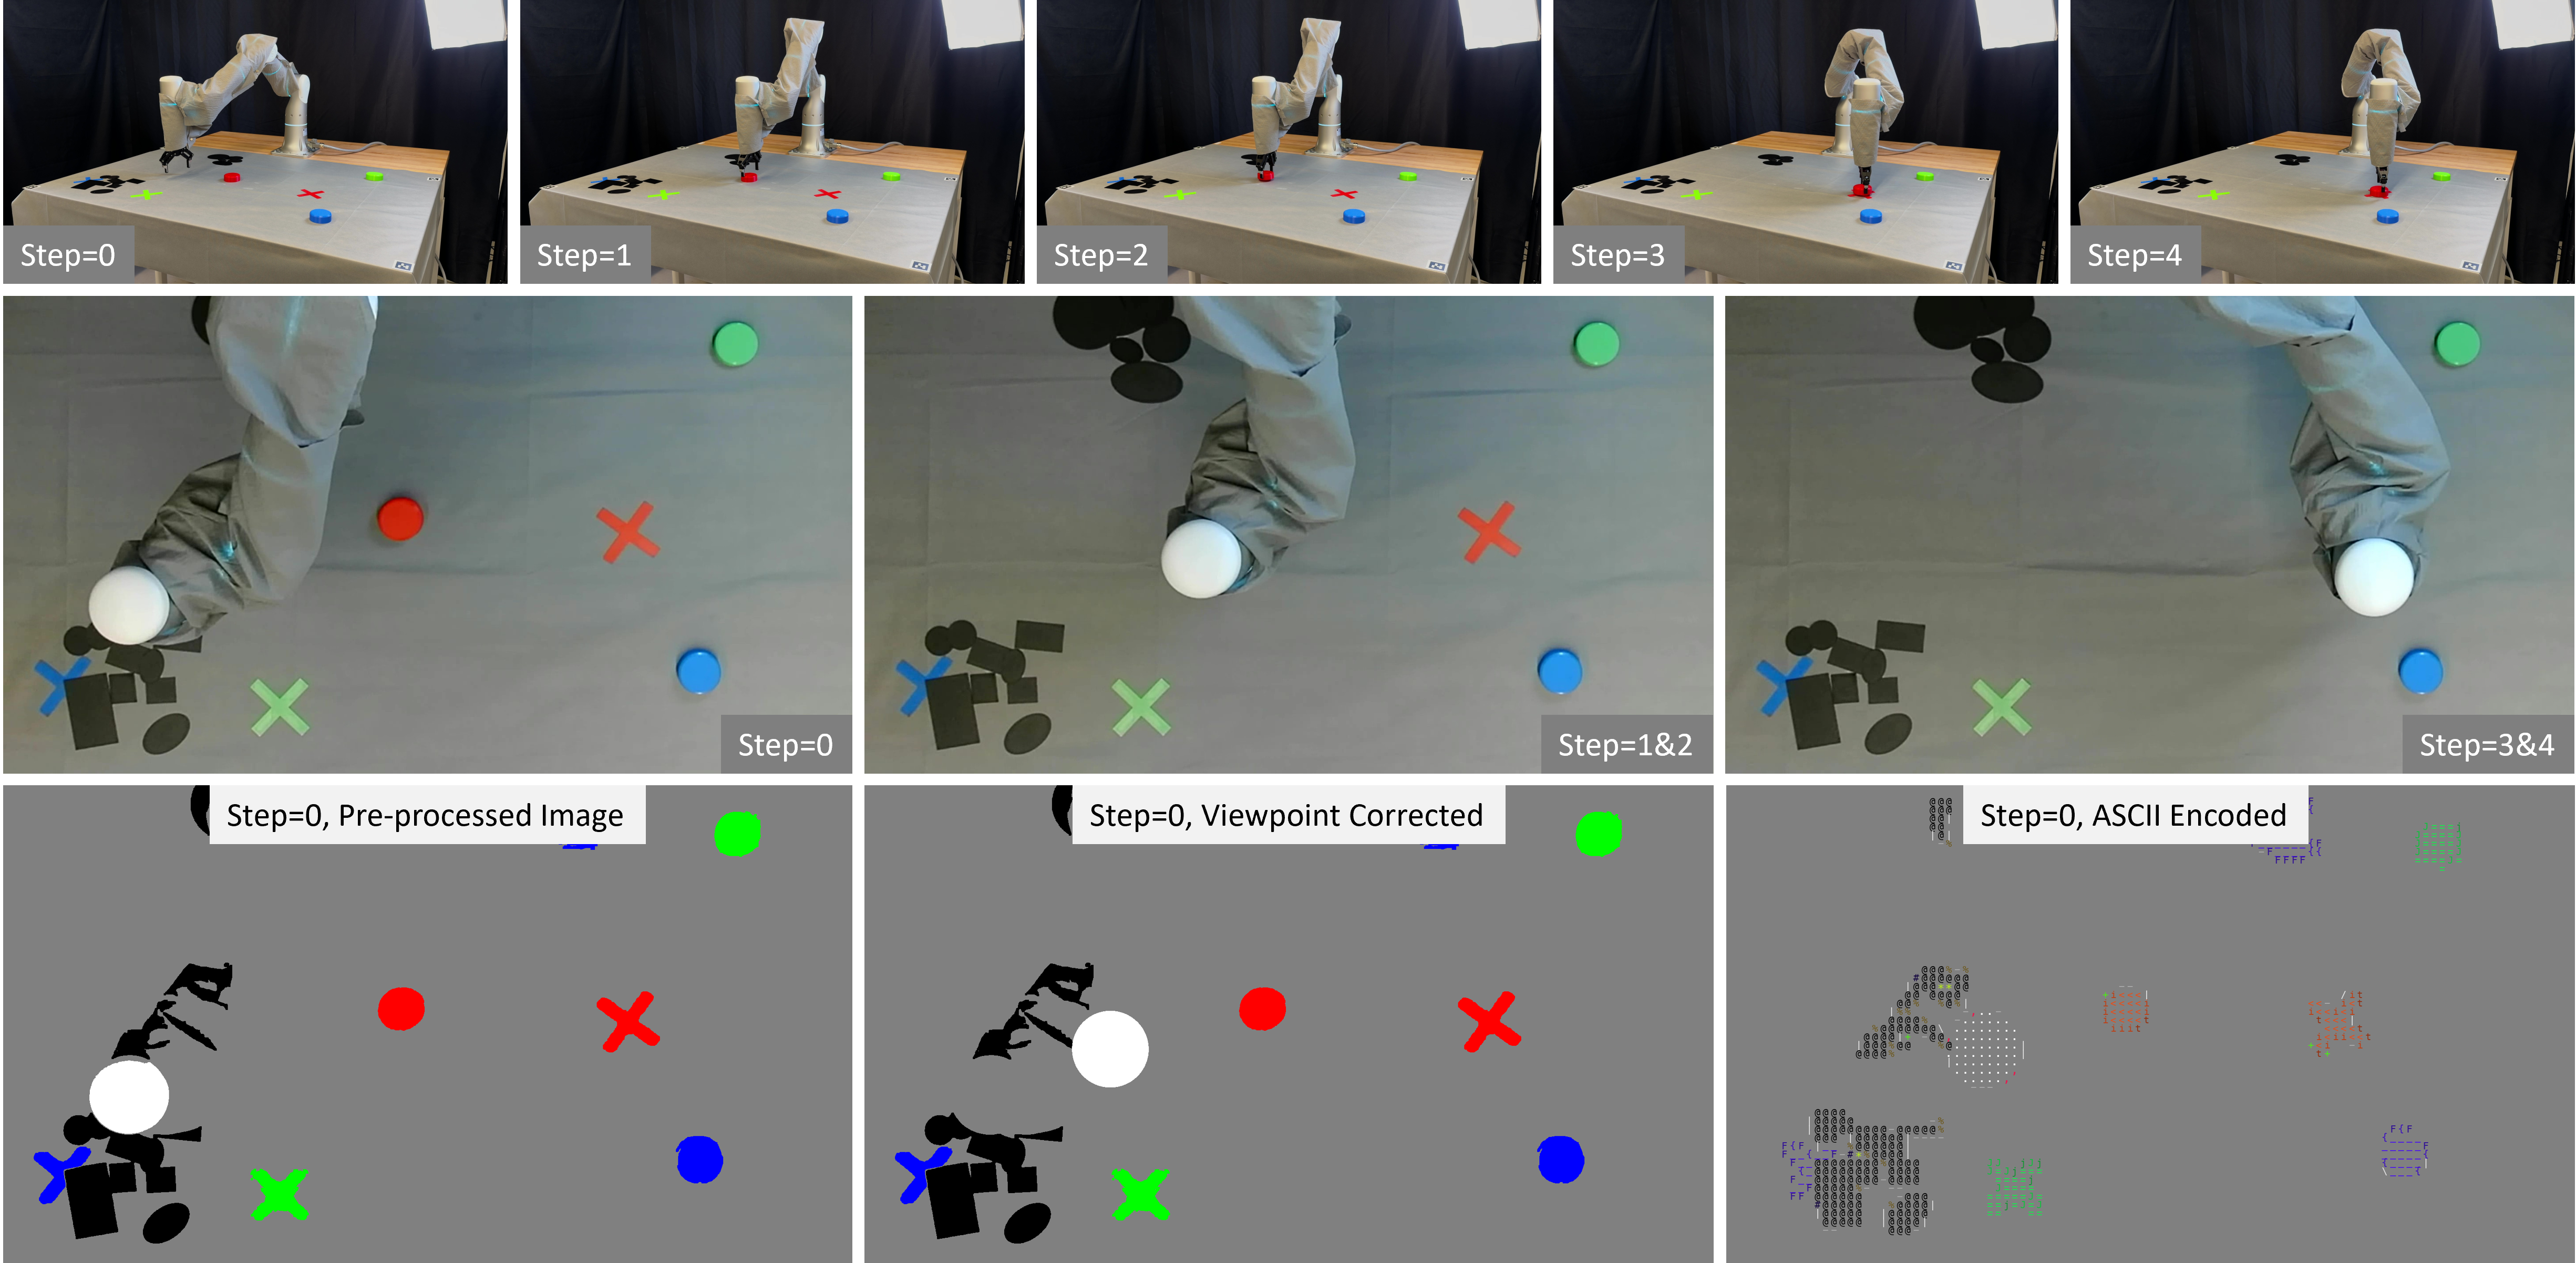
Language-conditioned control on a physical manipulator
Aerial construction
Published work
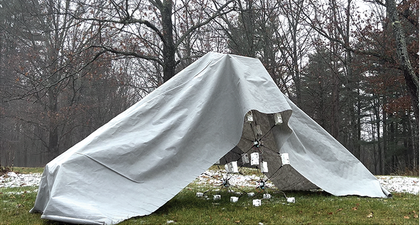
Rotorcraft-assembled frame; fabric placed by hand.
Related publications
View publicationsGripSnap: Reconfigurable Tool Use
Robot Learning, Planning & Autonomy
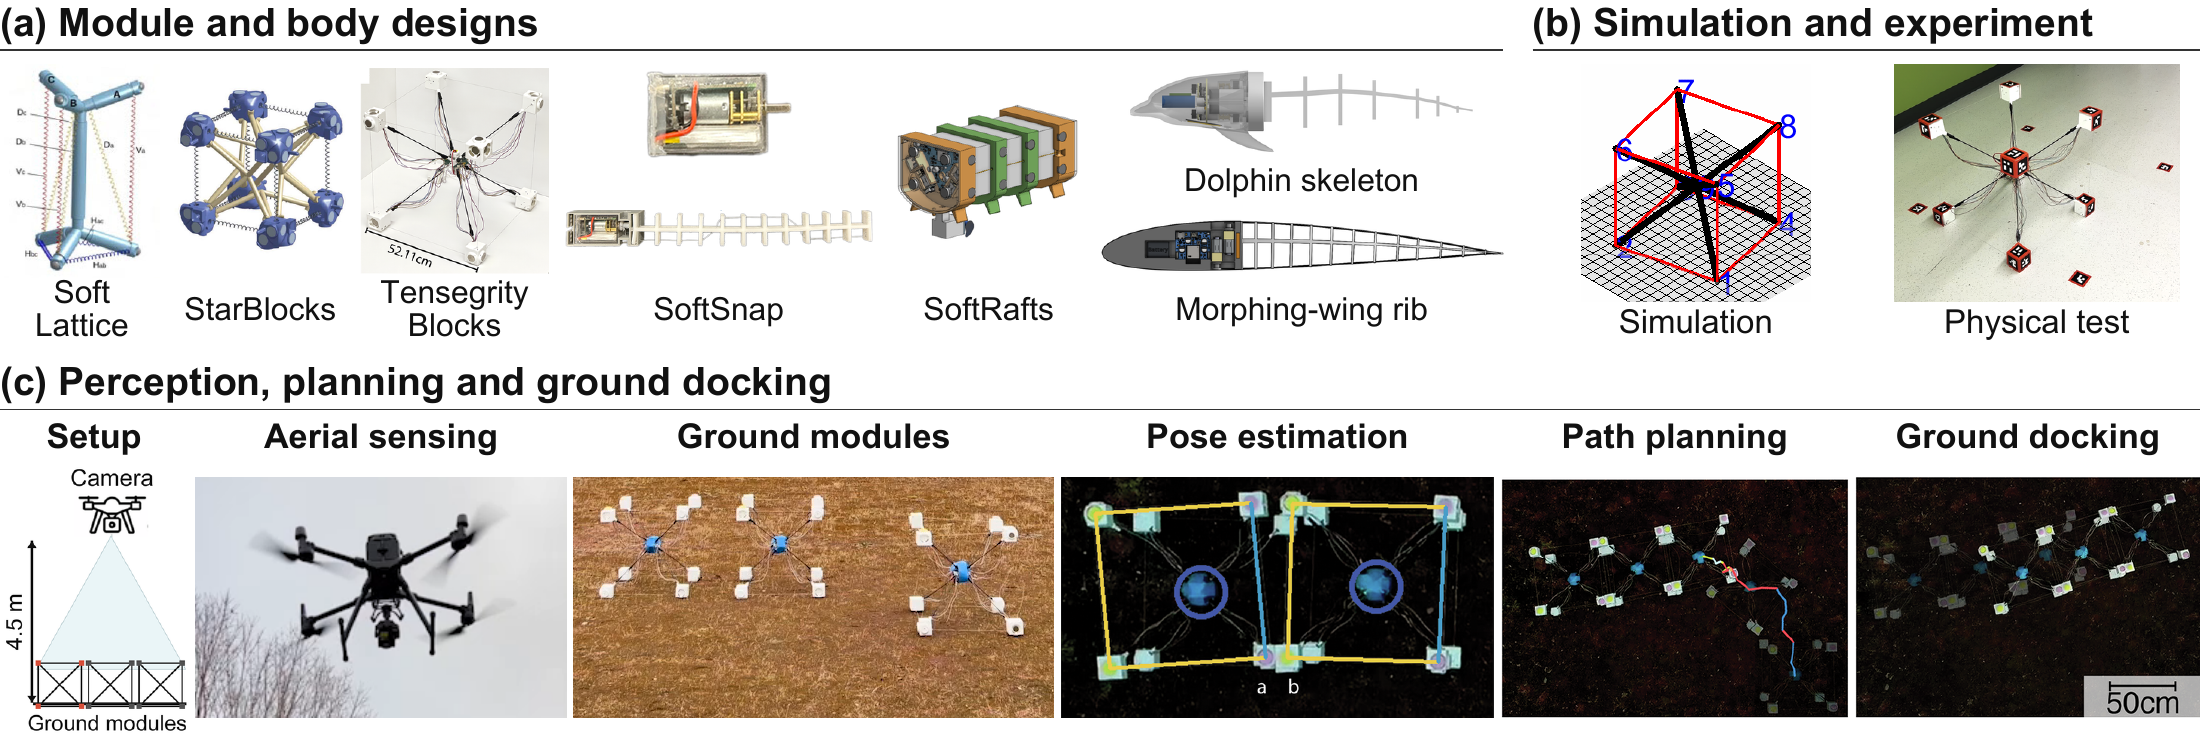
We study world models for policy learning, alongside perception and efficient motion planning for autonomous robot behavior.
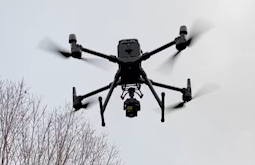
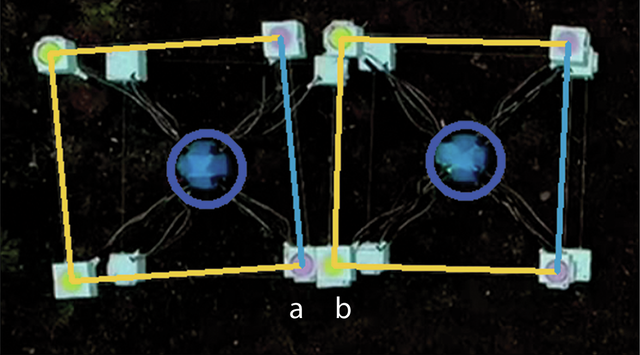
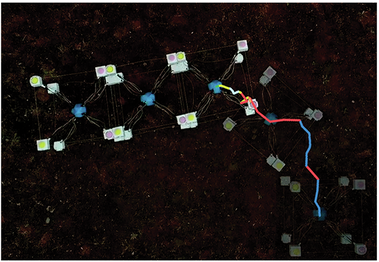
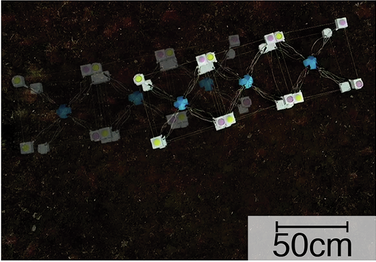
Aerial sensing supports vision-guided ground docking in Tensegrity-Blocks.
Selected publications
View publications- FlowMo-WM Preprint / Under review, 2026
- PLRC* IROS, 2020
- SeePerSea IEEE Transactions on Field Robotics, 2025
- LLM Swarm Robotics IROS, 2025
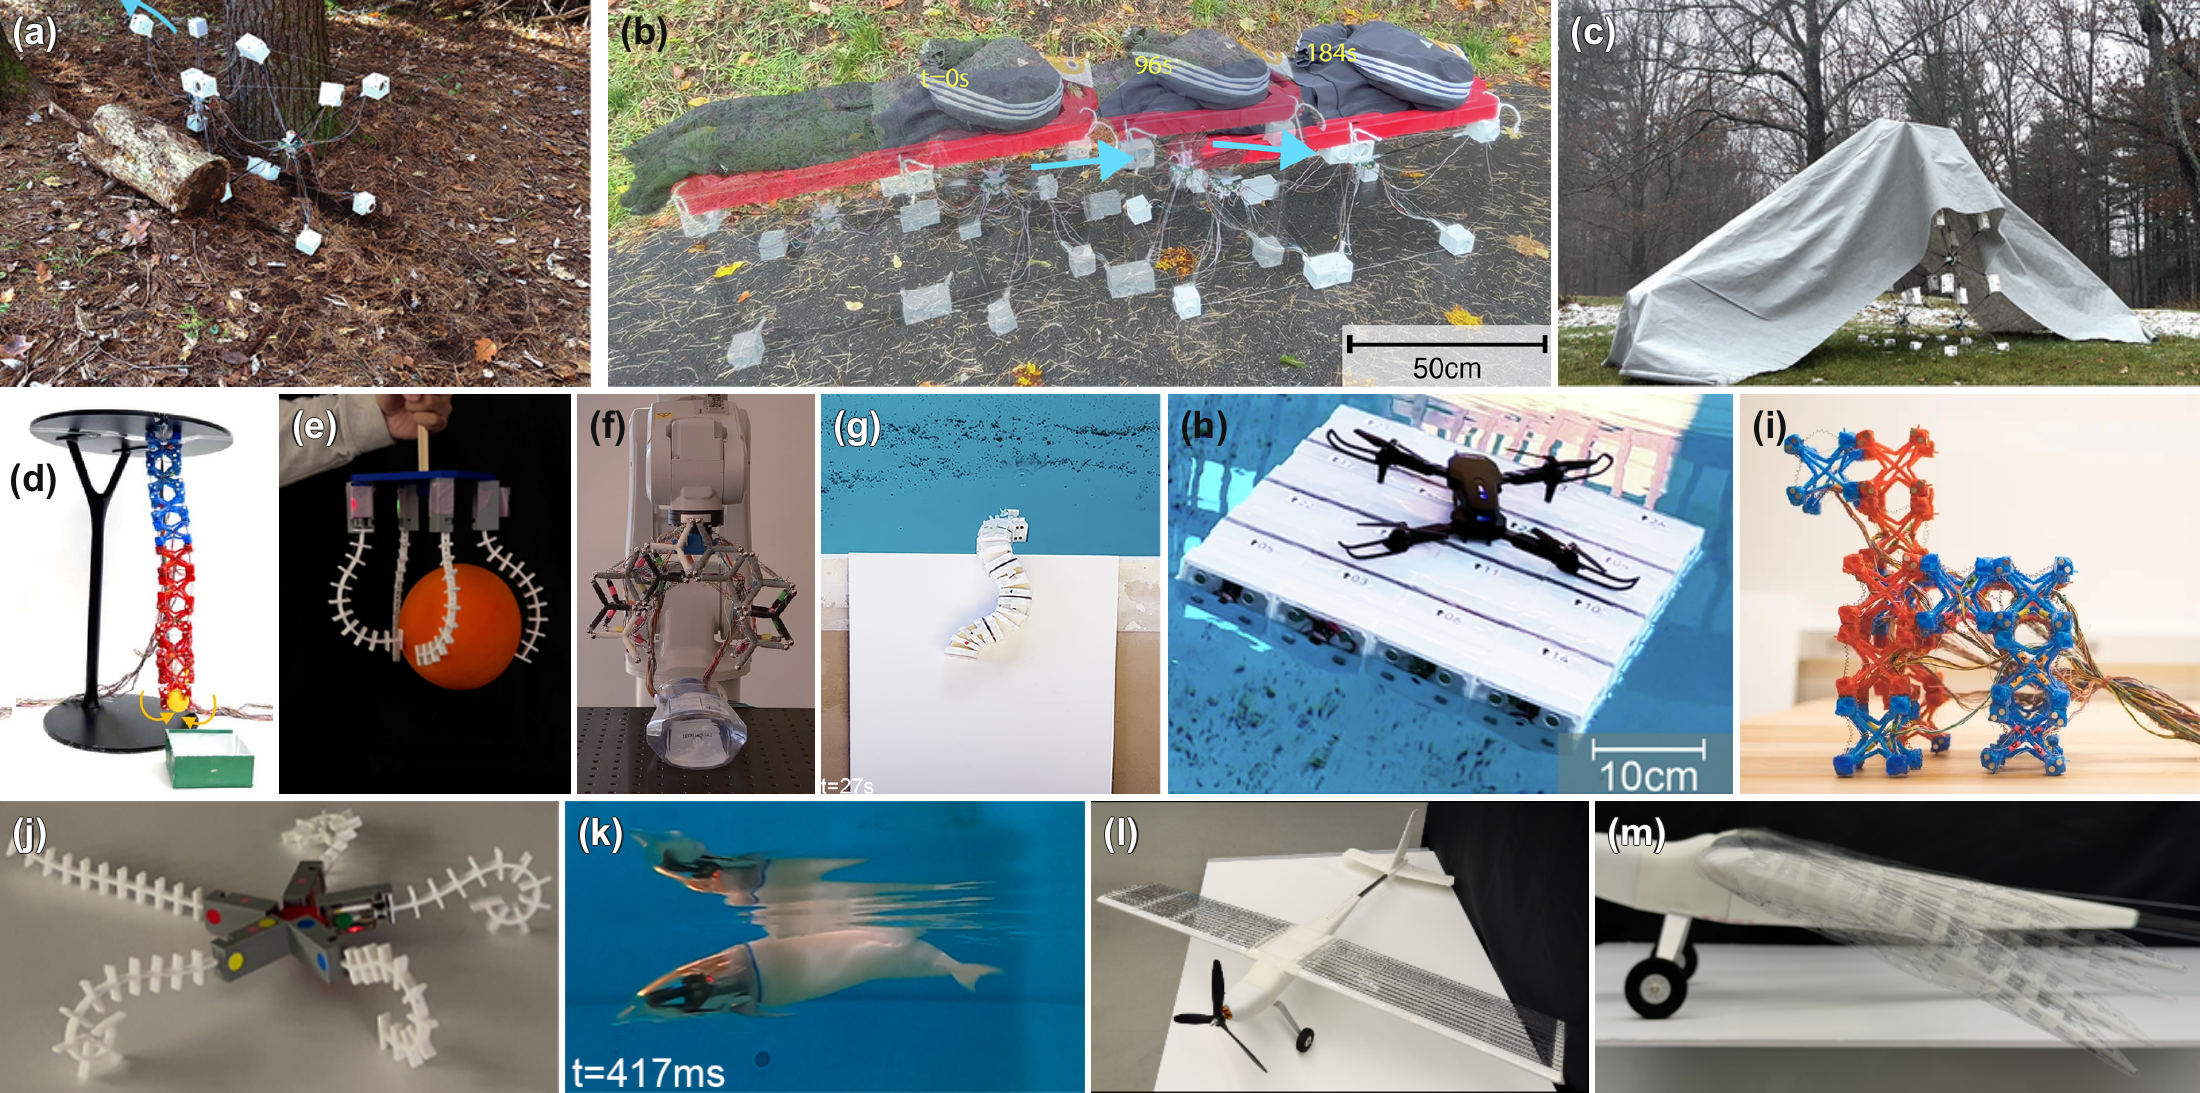
Softness, modularity, and tensegrity create robot bodies that can move, manipulate, change shape, and work together.
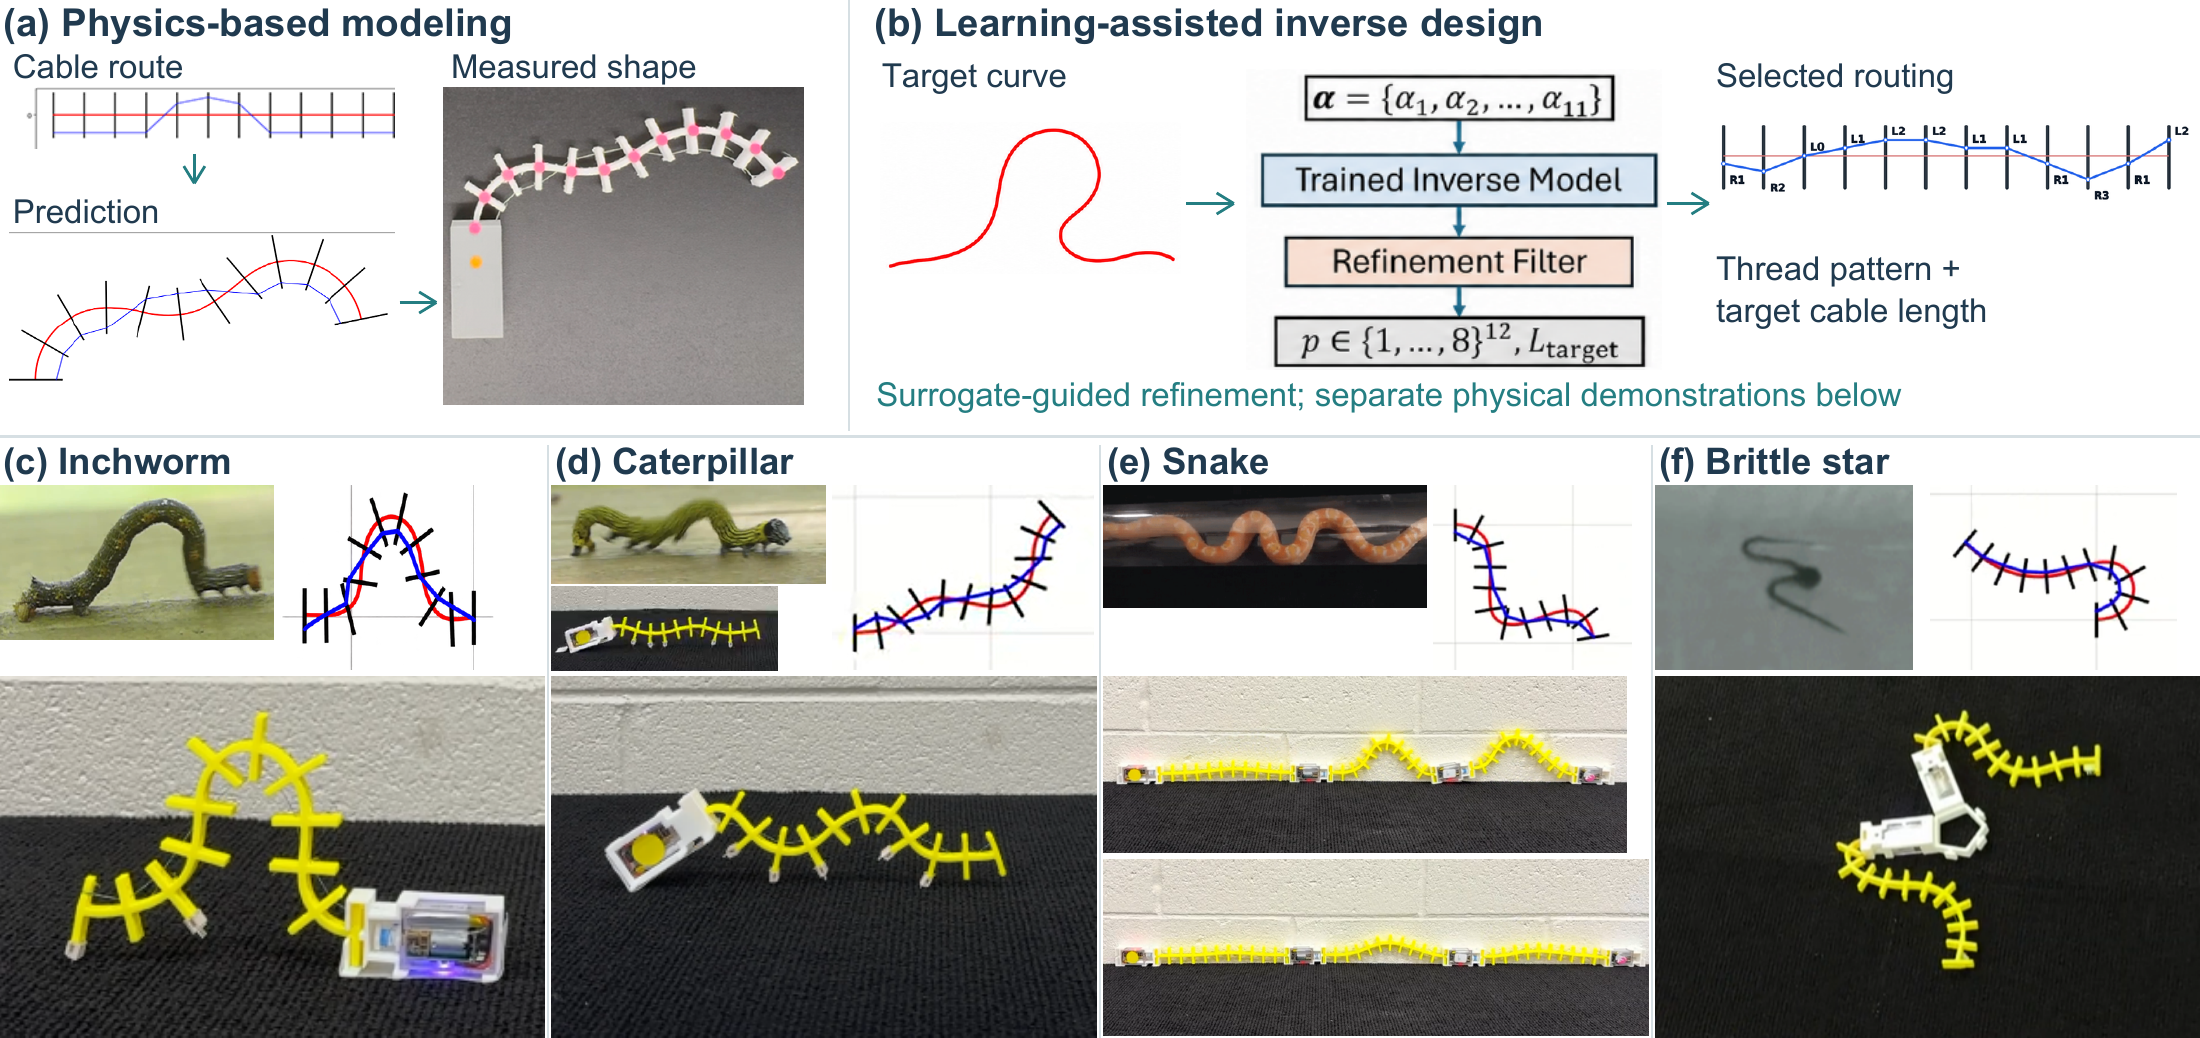
Physics-based modeling and learning-assisted inverse design connect desired shapes and behaviors to realizable robot configurations.
Task-conditioned generation and simulation feedback guide the design of modular robot bodies, toward a design-build-test loop.
We study world models for policy learning, alongside perception and efficient motion planning for autonomous robot behavior.
Publications
Robot Platforms & Actuation
-
Design, Fabrication, and Testing of a Tensegrity Morphing Aircraft